Define an objective that maximizes net profit by combining profits with optional planning-unit and action-cost penalties.
Usage
add_objective_max_net_profit(
  x,
  profit_col = "profit",
  include_pu_cost = TRUE,
  include_action_cost = TRUE,
  actions = NULL,
  alias = NULL
)
Arguments
- x
A
Problemobject.- profit_col
Character string giving the profit column in the stored profit table.
- include_pu_cost
Logical. If
TRUE, subtract planning-unit costs.- include_action_cost
Logical. If
TRUE, subtract action costs.- actions
Optional subset of actions to include in the profit and action-cost terms. Values may match
x$data$actions$idand, if present,x$data$actions$action_set.- alias
Optional identifier used to register this objective for multi-objective workflows.
Details
Use this function when decisions generate returns and the objective should optimize the resulting net balance after subtracting selected cost components.
Let:
\(x_{ia} \in \{0,1\}\) denote whether action \(a\) is selected in planning unit \(i\),
\(w_i \in \{0,1\}\) denote whether planning unit \(i\) is selected,
\(\pi_{ia}\) denote the profit associated with decision \((i,a)\),
\(c_i^{PU} \ge 0\) denote the planning-unit cost,
\(c_{ia}^{A} \ge 0\) denote the action cost.
In its most general form, the objective is:
$$ \max \left( \sum_{(i,a) \in \mathcal{D}^{\star}} \pi_{ia} x_{ia} - \sum_{i \in \mathcal{I}} c_i^{PU} w_i - \sum_{(i,a) \in \mathcal{D}^{\star}} c_{ia}^{A} x_{ia} \right), $$
where \(\mathcal{D}^{\star}\) denotes the subset of feasible planning unit–action decisions included in the objective.
If actions = NULL, all feasible actions contribute to both the profit
term and the action-cost term.
If actions is provided, the profit term and the action-cost term are
restricted to that subset. The planning-unit cost term, if included, remains
global.
If include_pu_cost = FALSE, the planning-unit cost term is omitted.
If include_action_cost = FALSE, the action-cost term is omitted.
Repeated calls
With alias = NULL, one explicit single objective can be defined per
problem; a second unaliased definition raises an error. With an alias,
objectives accumulate under distinct names; a repeated alias raises an error.
Aliased definitions preserve an explicitly configured single objective.
To compare alternatives, start from the problem before its objective was added.
References
Polasky, S., et al. (2008). Where to put things? Spatial land management to sustain biodiversity and economic returns. Biological Conservation, 141, 1505–1524. doi:10.1016/j.biocon.2008.03.022
Chan, K. M. A., Hoshizaki, L., and Klinkenberg, B. (2011). Ecosystem services in conservation planning: targeted benefits vs. co-benefits or costs? PLOS ONE, 6, e24378. doi:10.1371/journal.pone.0024378
Examples
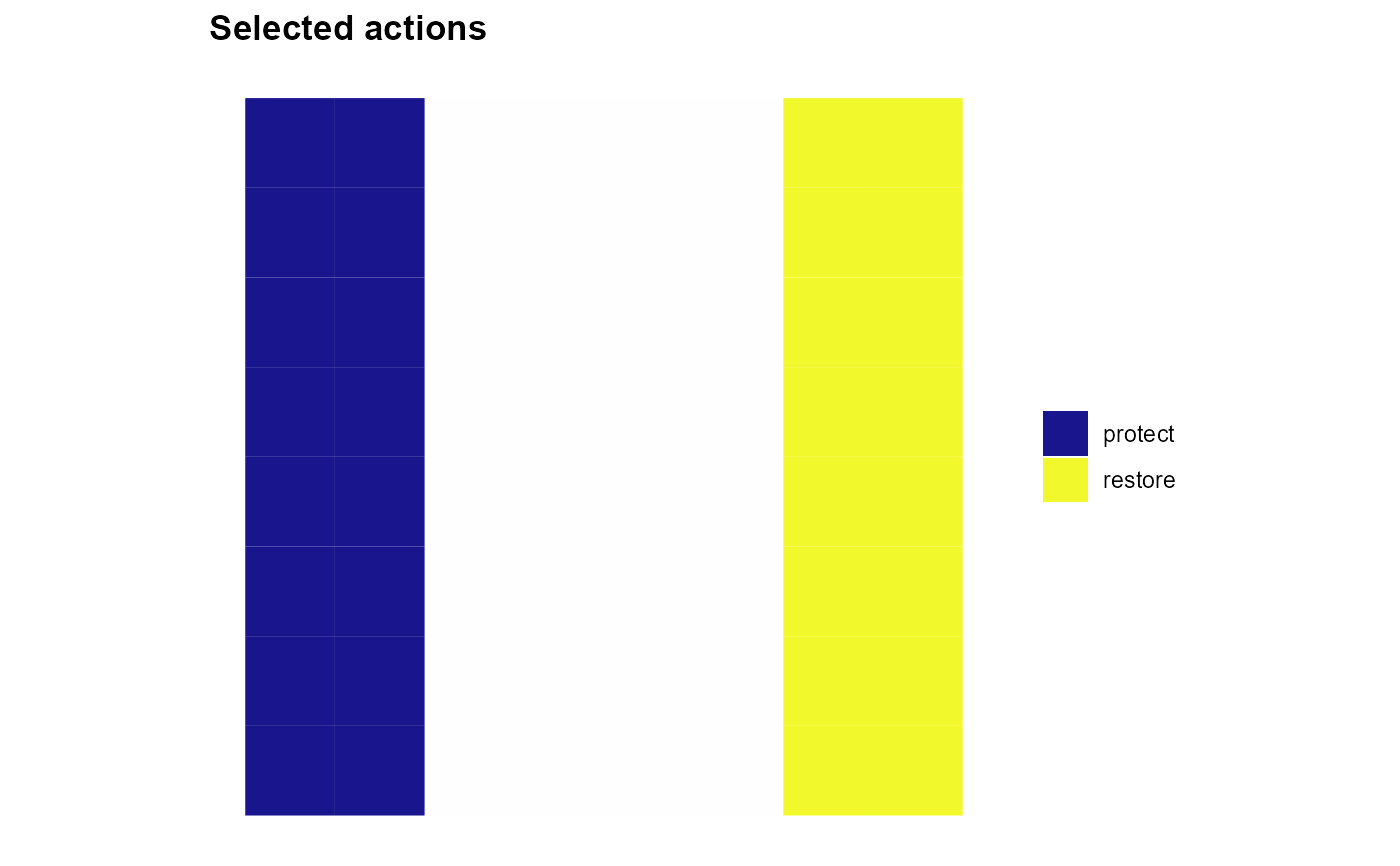
# EXAMPLE: Maximise returns minus implementation costs
#
# Use the same west-to-east profit pattern as above, but now
# charge 9.5 monetary units for every selected action. Some
# locations may no longer generate a positive net return.
sim <- load_sim_multiaction()
returns <- sim$action_costs[, c("pu", "action")]
x_coord <- sim$planning_units$x[
  match(returns$pu, sim$planning_units$id)
]
returns$profit <- ifelse(
  returns$action == "protect", 12 - x_coord, 4 + x_coord
)

p <- create_problem(
  pu = sim$planning_units,
  features = sim$features,
  dist_features = sim$dist_features,
  cost = "cost"
) |>
  add_actions(sim$actions, cost = 9.5) |>
  add_profit(returns) |>
  add_objective_max_net_profit(include_pu_cost = FALSE, alias = "net_profit")

# Unlike gross profit maximisation, leaving a unit unmanaged
# can now be optimal when its best return is below its cost.
if (requireNamespace("rcbc", quietly = TRUE) &&
    requireNamespace("ggplot2", quietly = TRUE)) {
  solutions <- solve(set_solver_cbc(p, time_limit = 30, verbose = FALSE))
  get_objectives(solutions, format = "wide")
  plot_spatial_actions(solutions, layout = "single")
}